|
Elsa Forberger
PhD student, NSTGRO Fellow
My goal is to support large-scale In-Situ Resource Utilization (ISRU), construction, and transport operations on the lunar surface by ensuring robotic teams can adapt to the wear and tear caused by harsh extraterrestrial enviroments. To do so, my research centers around robust and adaptive control methods that can be used to identify and account for changes in capability. I am also interested in ways to incorperate knowledge of robot capabilities into high level task selection and planning.
|
|
|
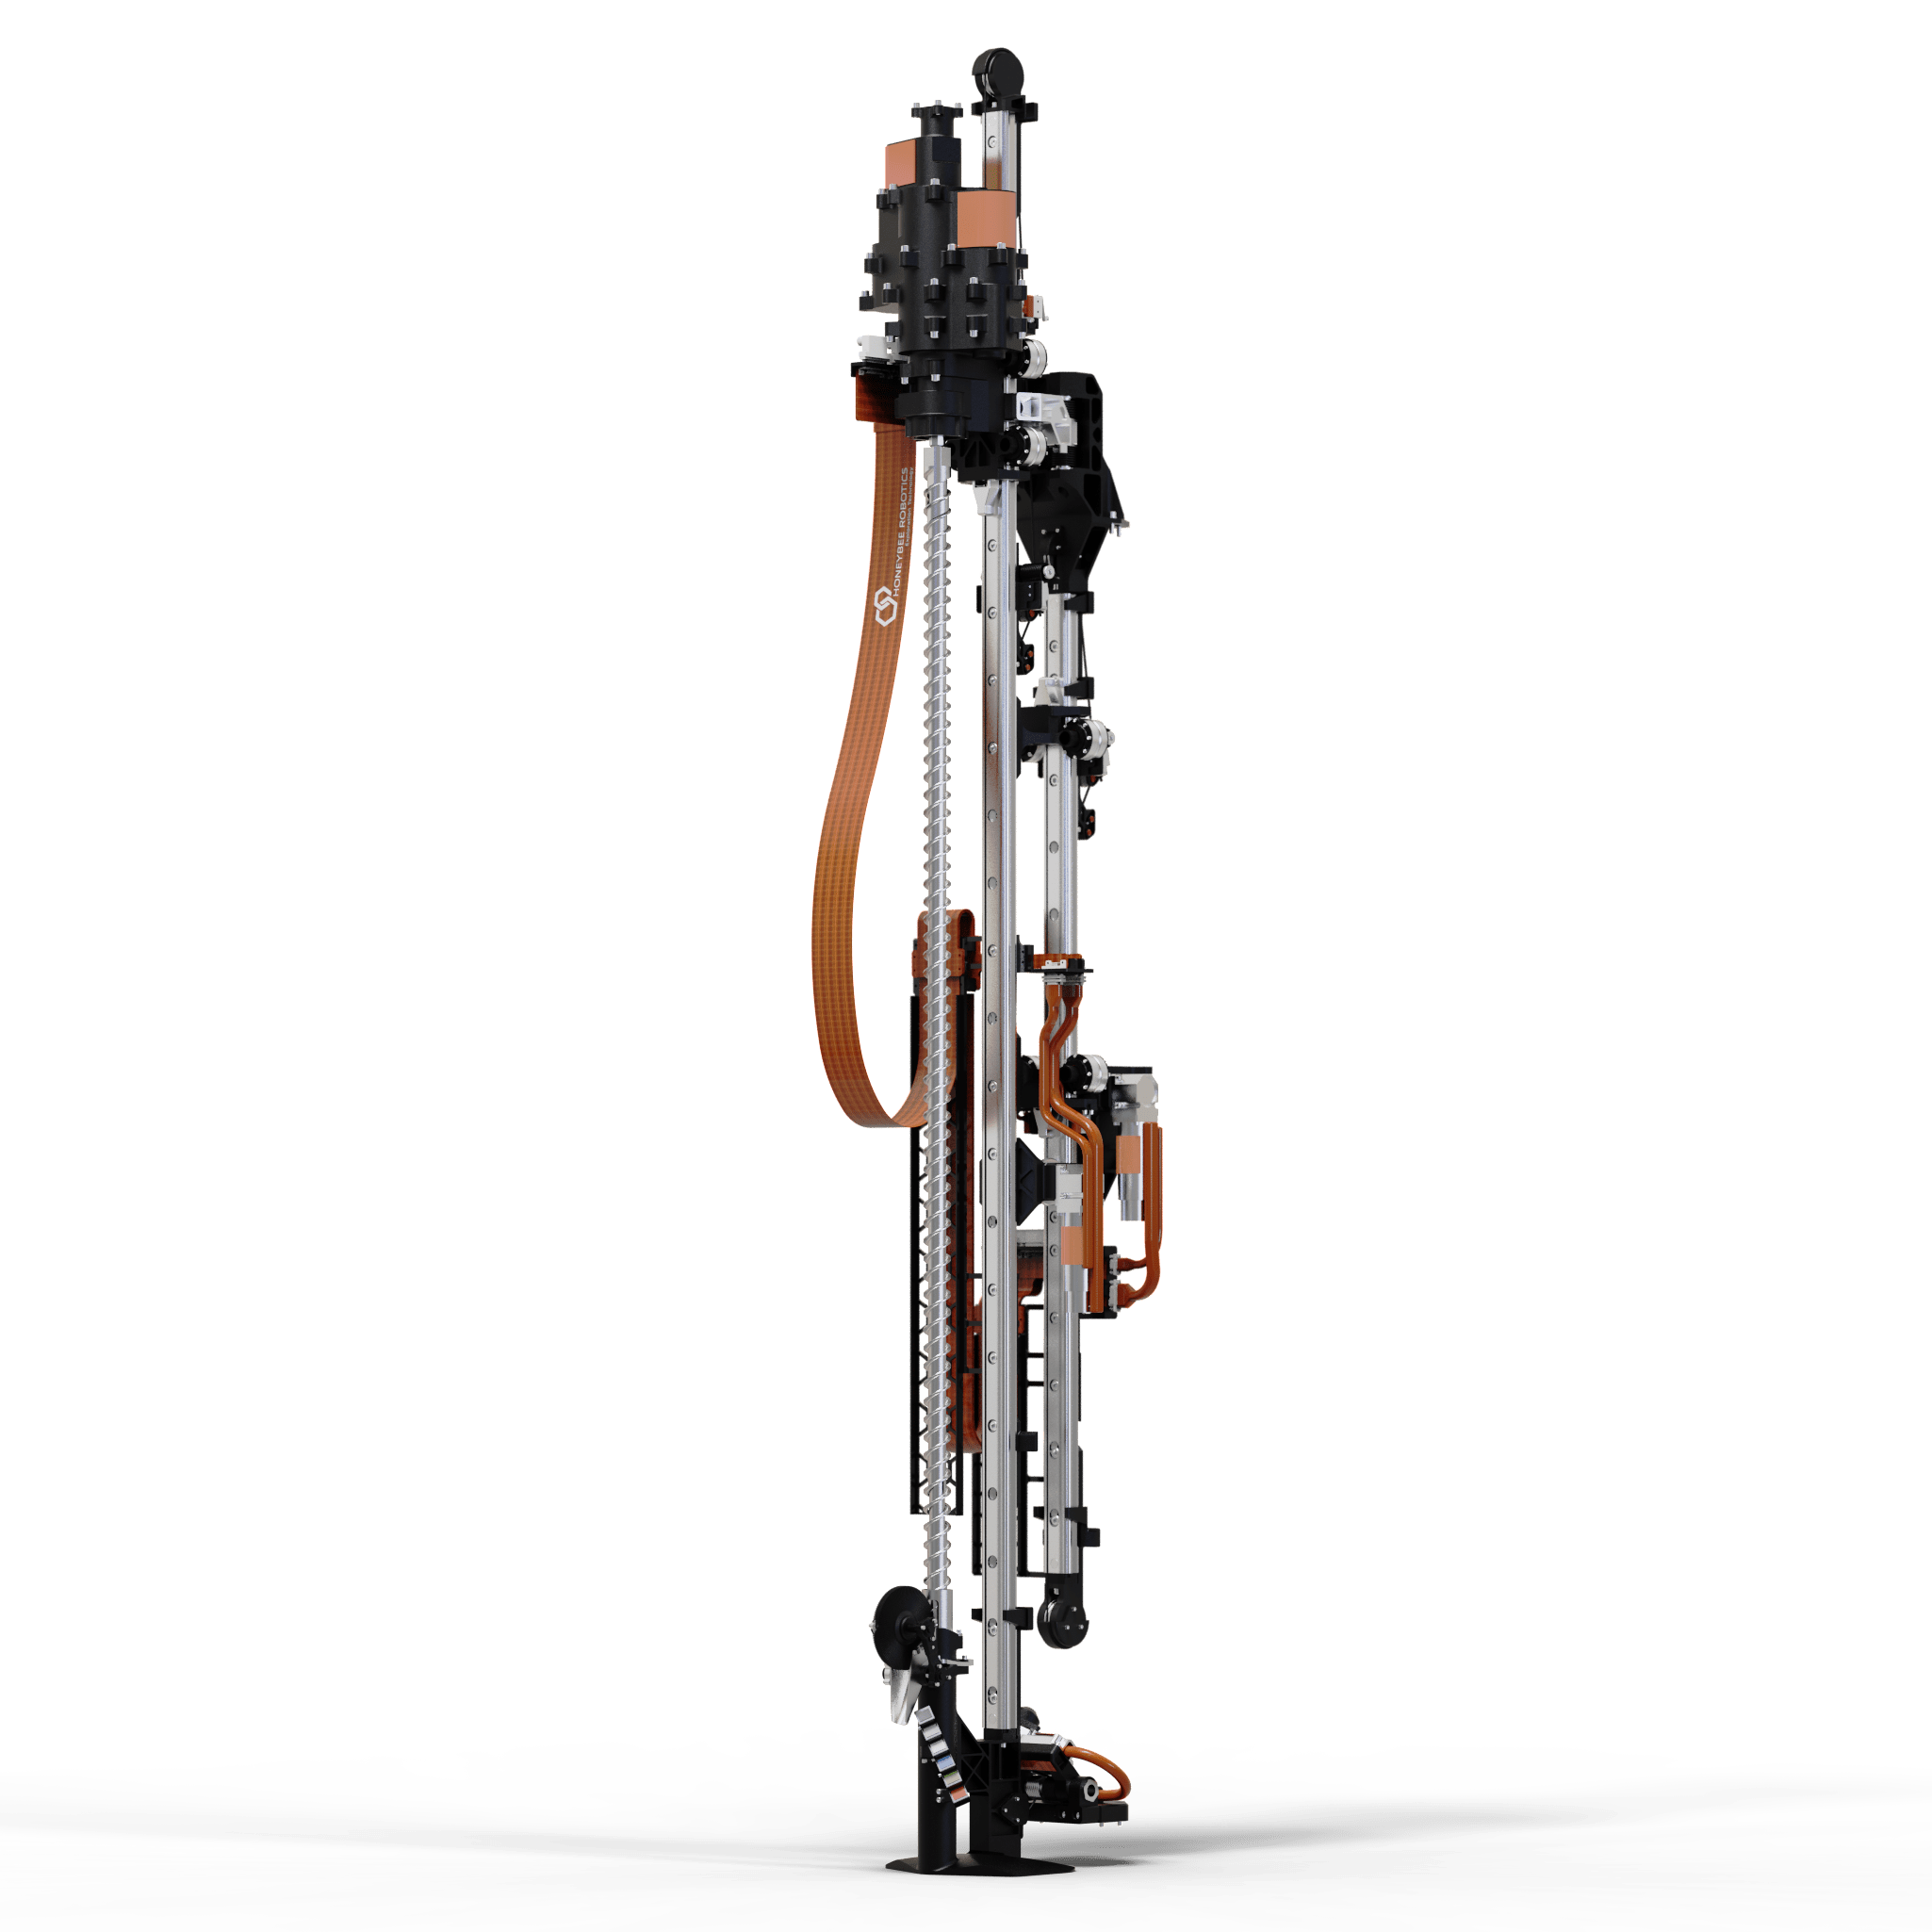
Fast Vibration-Based Autonomous Fault Detection for Extraterrestrial Drills
E. Forberger, S. Boelter, B. Glass, M. Gini RSS Workshop on Resource Constrained Systems, 2025 |
|
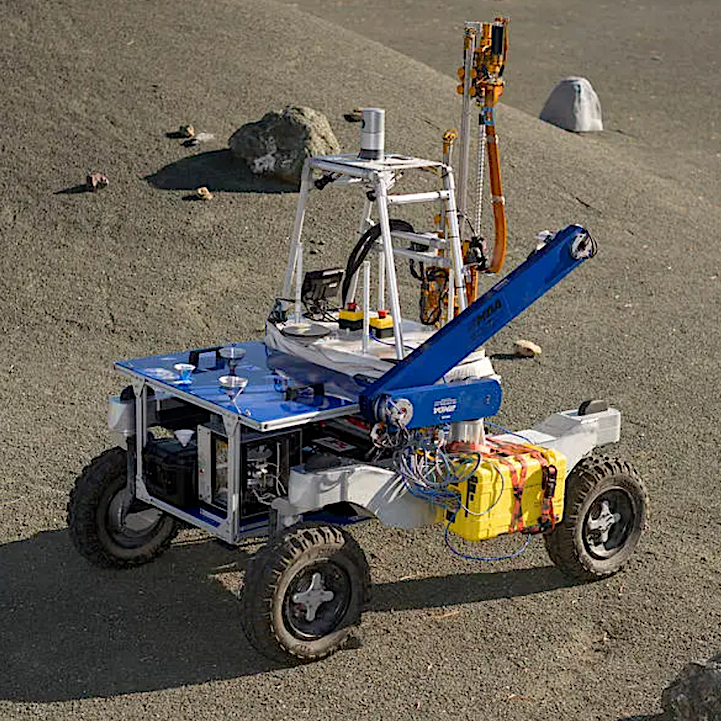
A Concept for Planetary Drilling Autonomy
S. Boelter, E. Temesgen, G. Brown, E. Forberger, B. Glass, M. Gini 2025 ICRA Workshop on Field Robotics, 2025 |
|
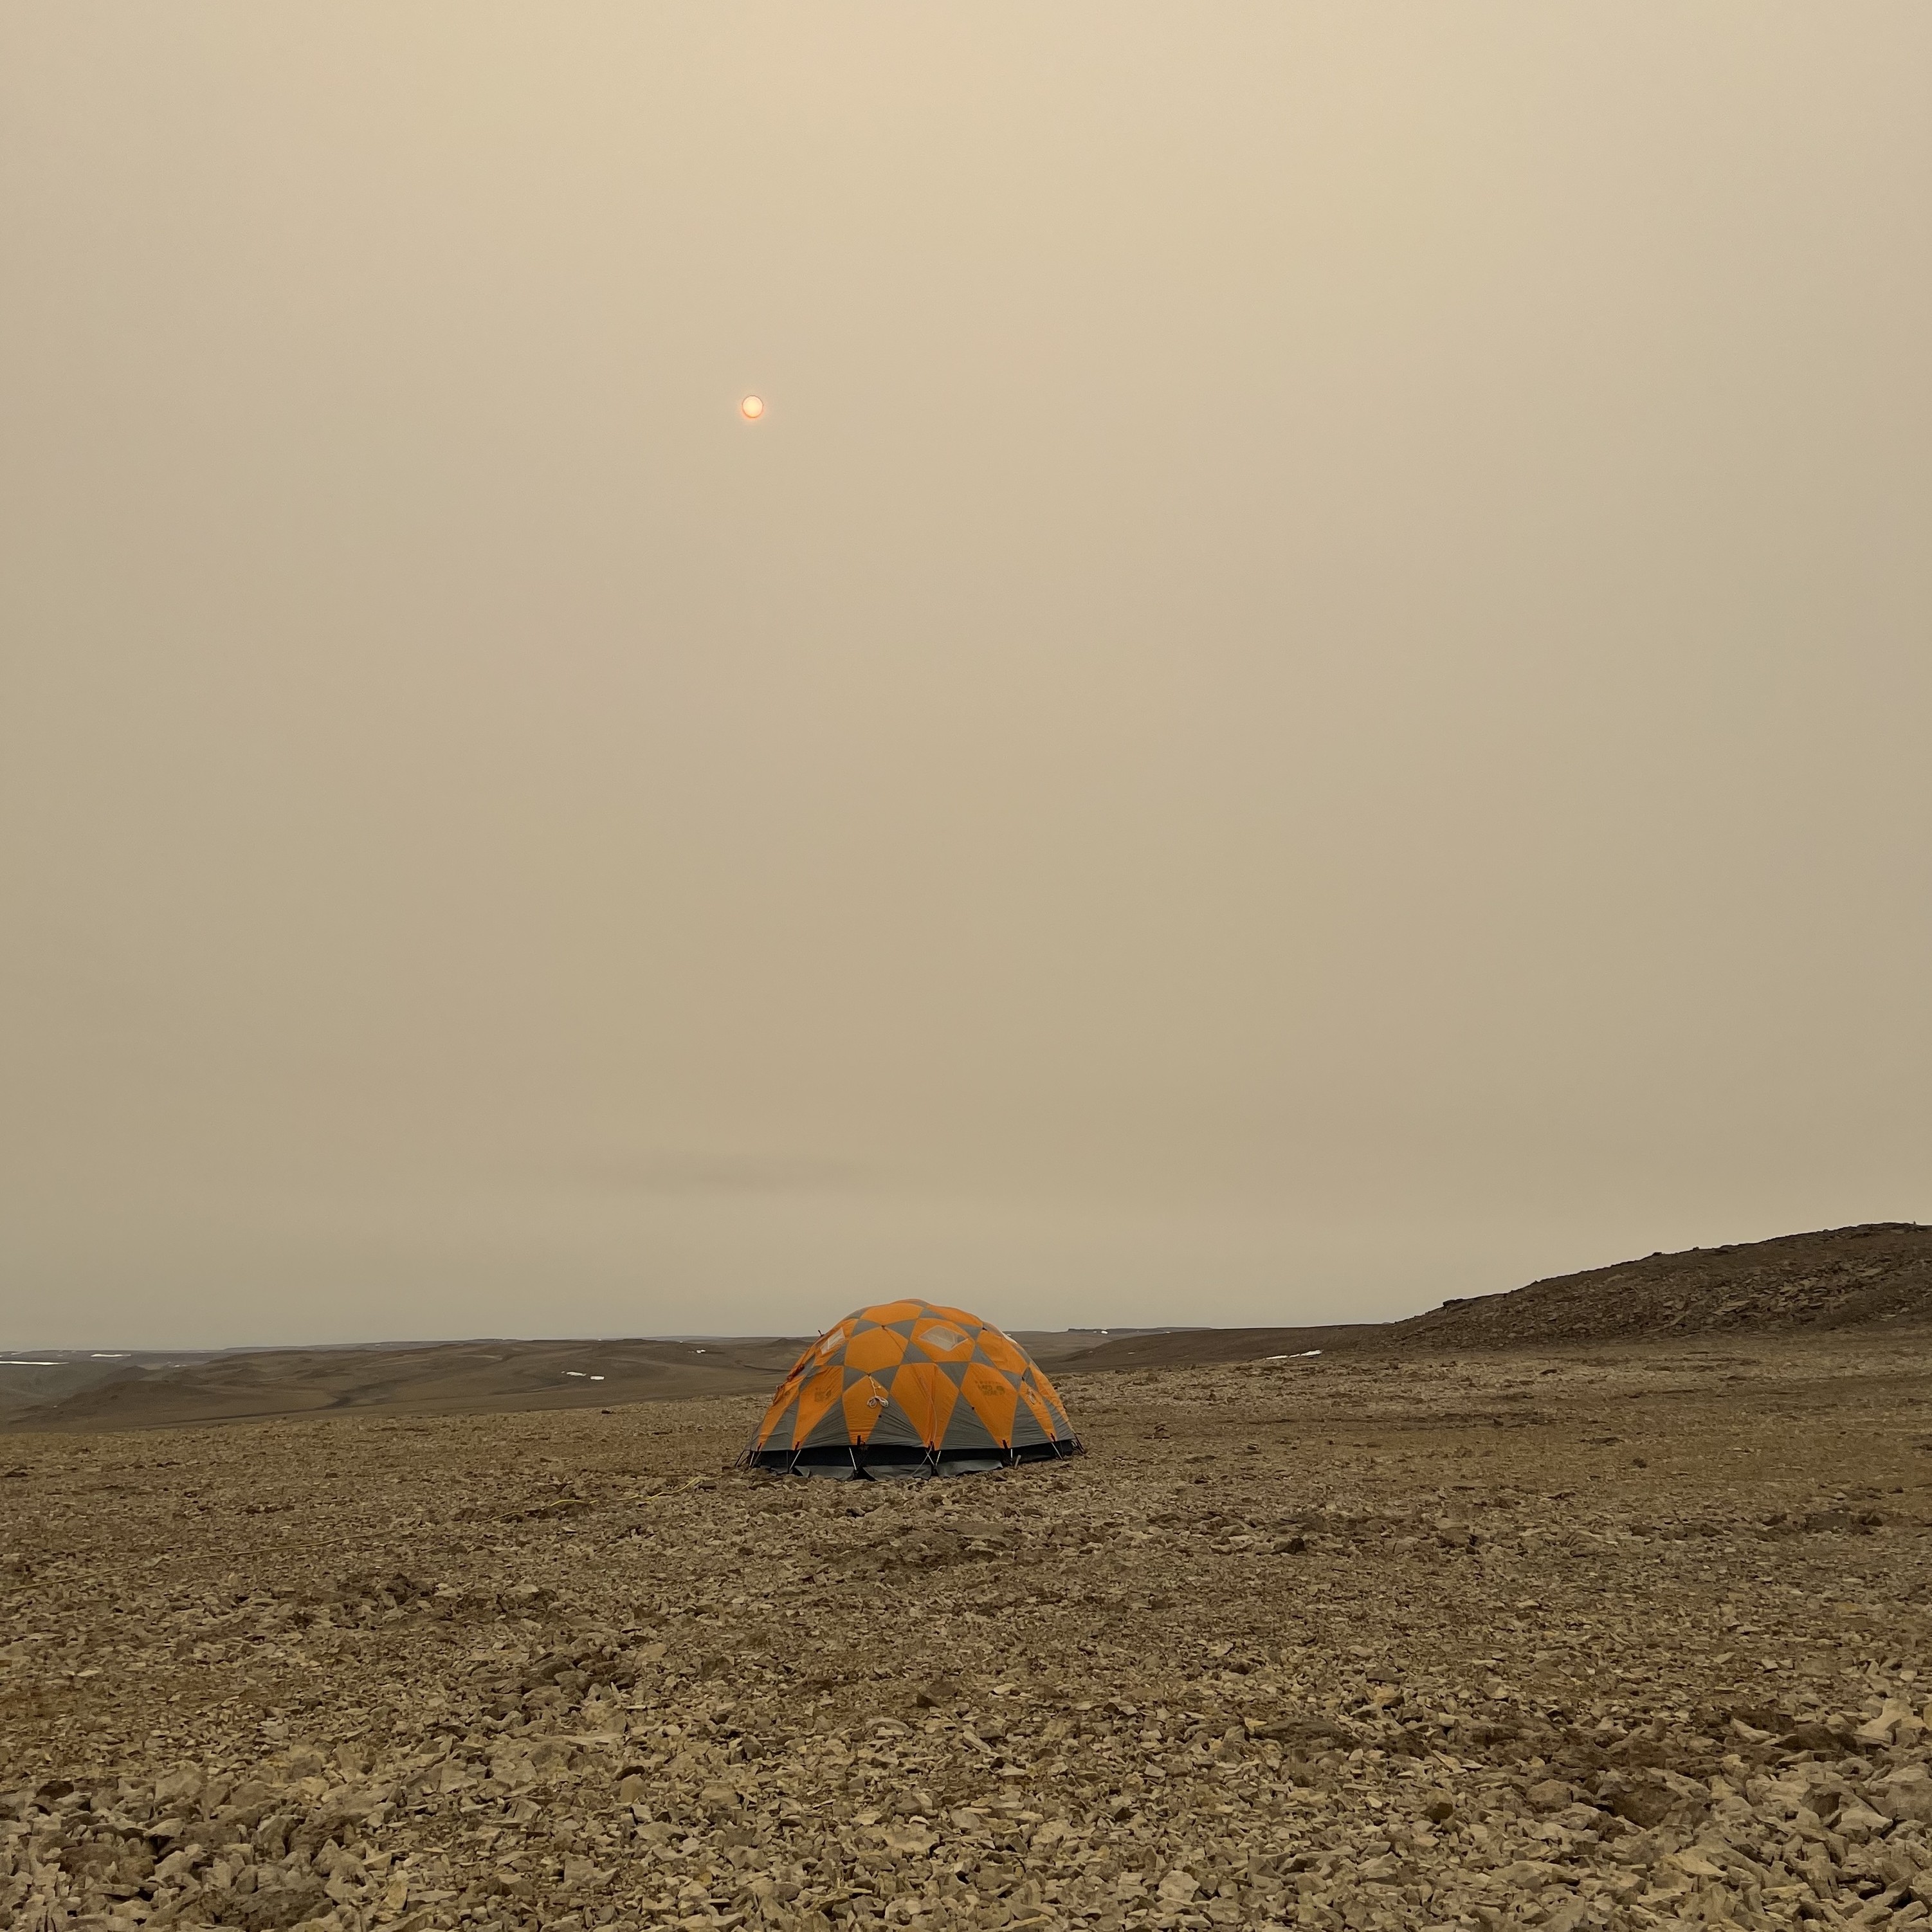
Abstract: Autonomy and Arctic Analog Testing for Planetary Drills
S. Boelter, E. Forberger, L. Weber, B. Glass, M. Gini 4th Ice Core Community Meeting (ICECOMM), 2025
|
|
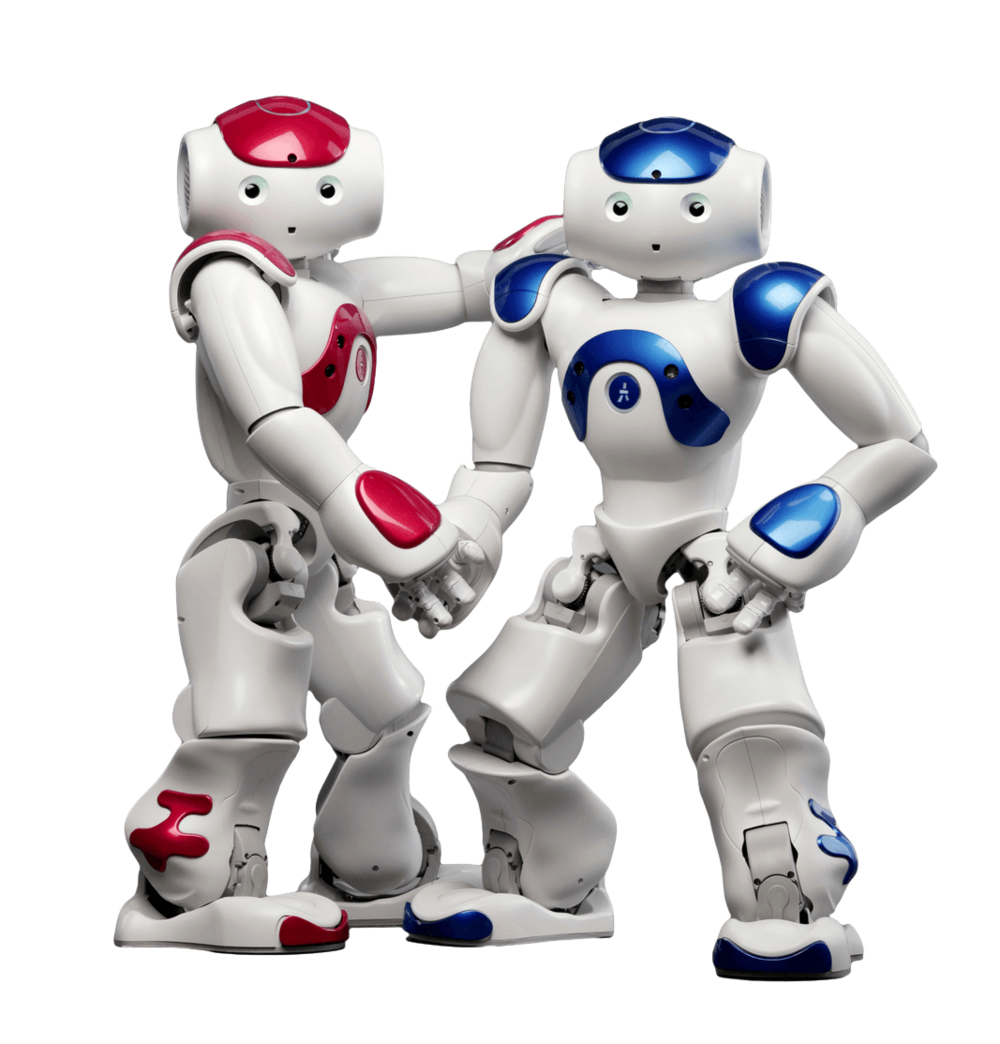
Social Robots in Service Contexts: Exploring the Rewards and Risks of Personalization and Re-embodiment
S. Reig, M. Luria, E. Forberger, I. Won, A. Steinfeld, J. Forlizzi, J. Zimmerman ACM Conference on Designing Interactive Systems, 2021 |
Experience |
|
LASER Lab, University of Southern California
Lab Member, 2026-Present Advised by Professor Keenan Albee |
|
Blue Origin
Software Engineer, 2025-2026 Space Resources Program, Blue Alchemist Project |
|
Next Generation Robotics Laboratory, University of Minnesota
Graduate Researcher, 2024-2025 Under Professor Maria Gini |
|
ASTER Labs
Research Scientist, 2022-2023 |
|
Interactive Robotics and Vision Lab, University of Minnesota
Undergraduate Researcher, 2020-2022 & Graduate Researcher, 2023 Under Professor Junaed Sattar |
|
Human Computer Interaction Institute, Carnege Mellon University
Undergraduate Researcher through NSF REU Program, 2020 Under Professor John Zimmerman |
Teaching and Mentorship |
|
Robotics (ME 5286), University of Minnesota
Graduate Teaching Assistant, Spring 2024 |
|
Code the Gap, University of Minnesota
Volunteer Coordinator, 2020-2022 |
|
Rocket Team, University of Minnesota
Graduate Mentor, 2023-2025. Firmware Lead, 2020 - 2024. |
Miscellanea |
|
Scans of NASA documents
I collect and scan older documents related to space exploration. |
|
Feel free to steal this website's source code. (As I did) Do not scrape the HTML from this page itself, as it includes analytics tags that you do not want on your own website — use the github code instead. Also, consider using Leonid Keselman's Jekyll fork of this page. |